
Helion
Custom 10-inch long-range FPV drone — 30 min flight, 2.2 kg

I build autonomous machines and intelligent software, from custom UAVs and surface vessels to machine-learning tools and high-performance runtimes.
View Projects ↓I'm an AI & Robotics Engineer with a background in both computer science and electronics. My work sits at the intersection of machine learning research and real hardware — I don't just train models, I deploy them on edge devices, integrate them with flight controllers, and make them run on resource-constrained systems where every millisecond matters.
I approach problems from the system level down: if I can't understand the full stack — from the transistor to the transformer — I don't feel like I truly understand it. That means building neural network compilers from scratch in Rust, writing bare-metal flight control inference loops, and designing the PCBs my code runs on. Every project is an opportunity to own the whole pipeline.
I care about open source, about building tools people actually want to use, and about the idea that the best research is research you can run on real hardware — not just in a notebook.
Custom 10-inch long-range FPV drone — 30 min flight, 2.2 kg
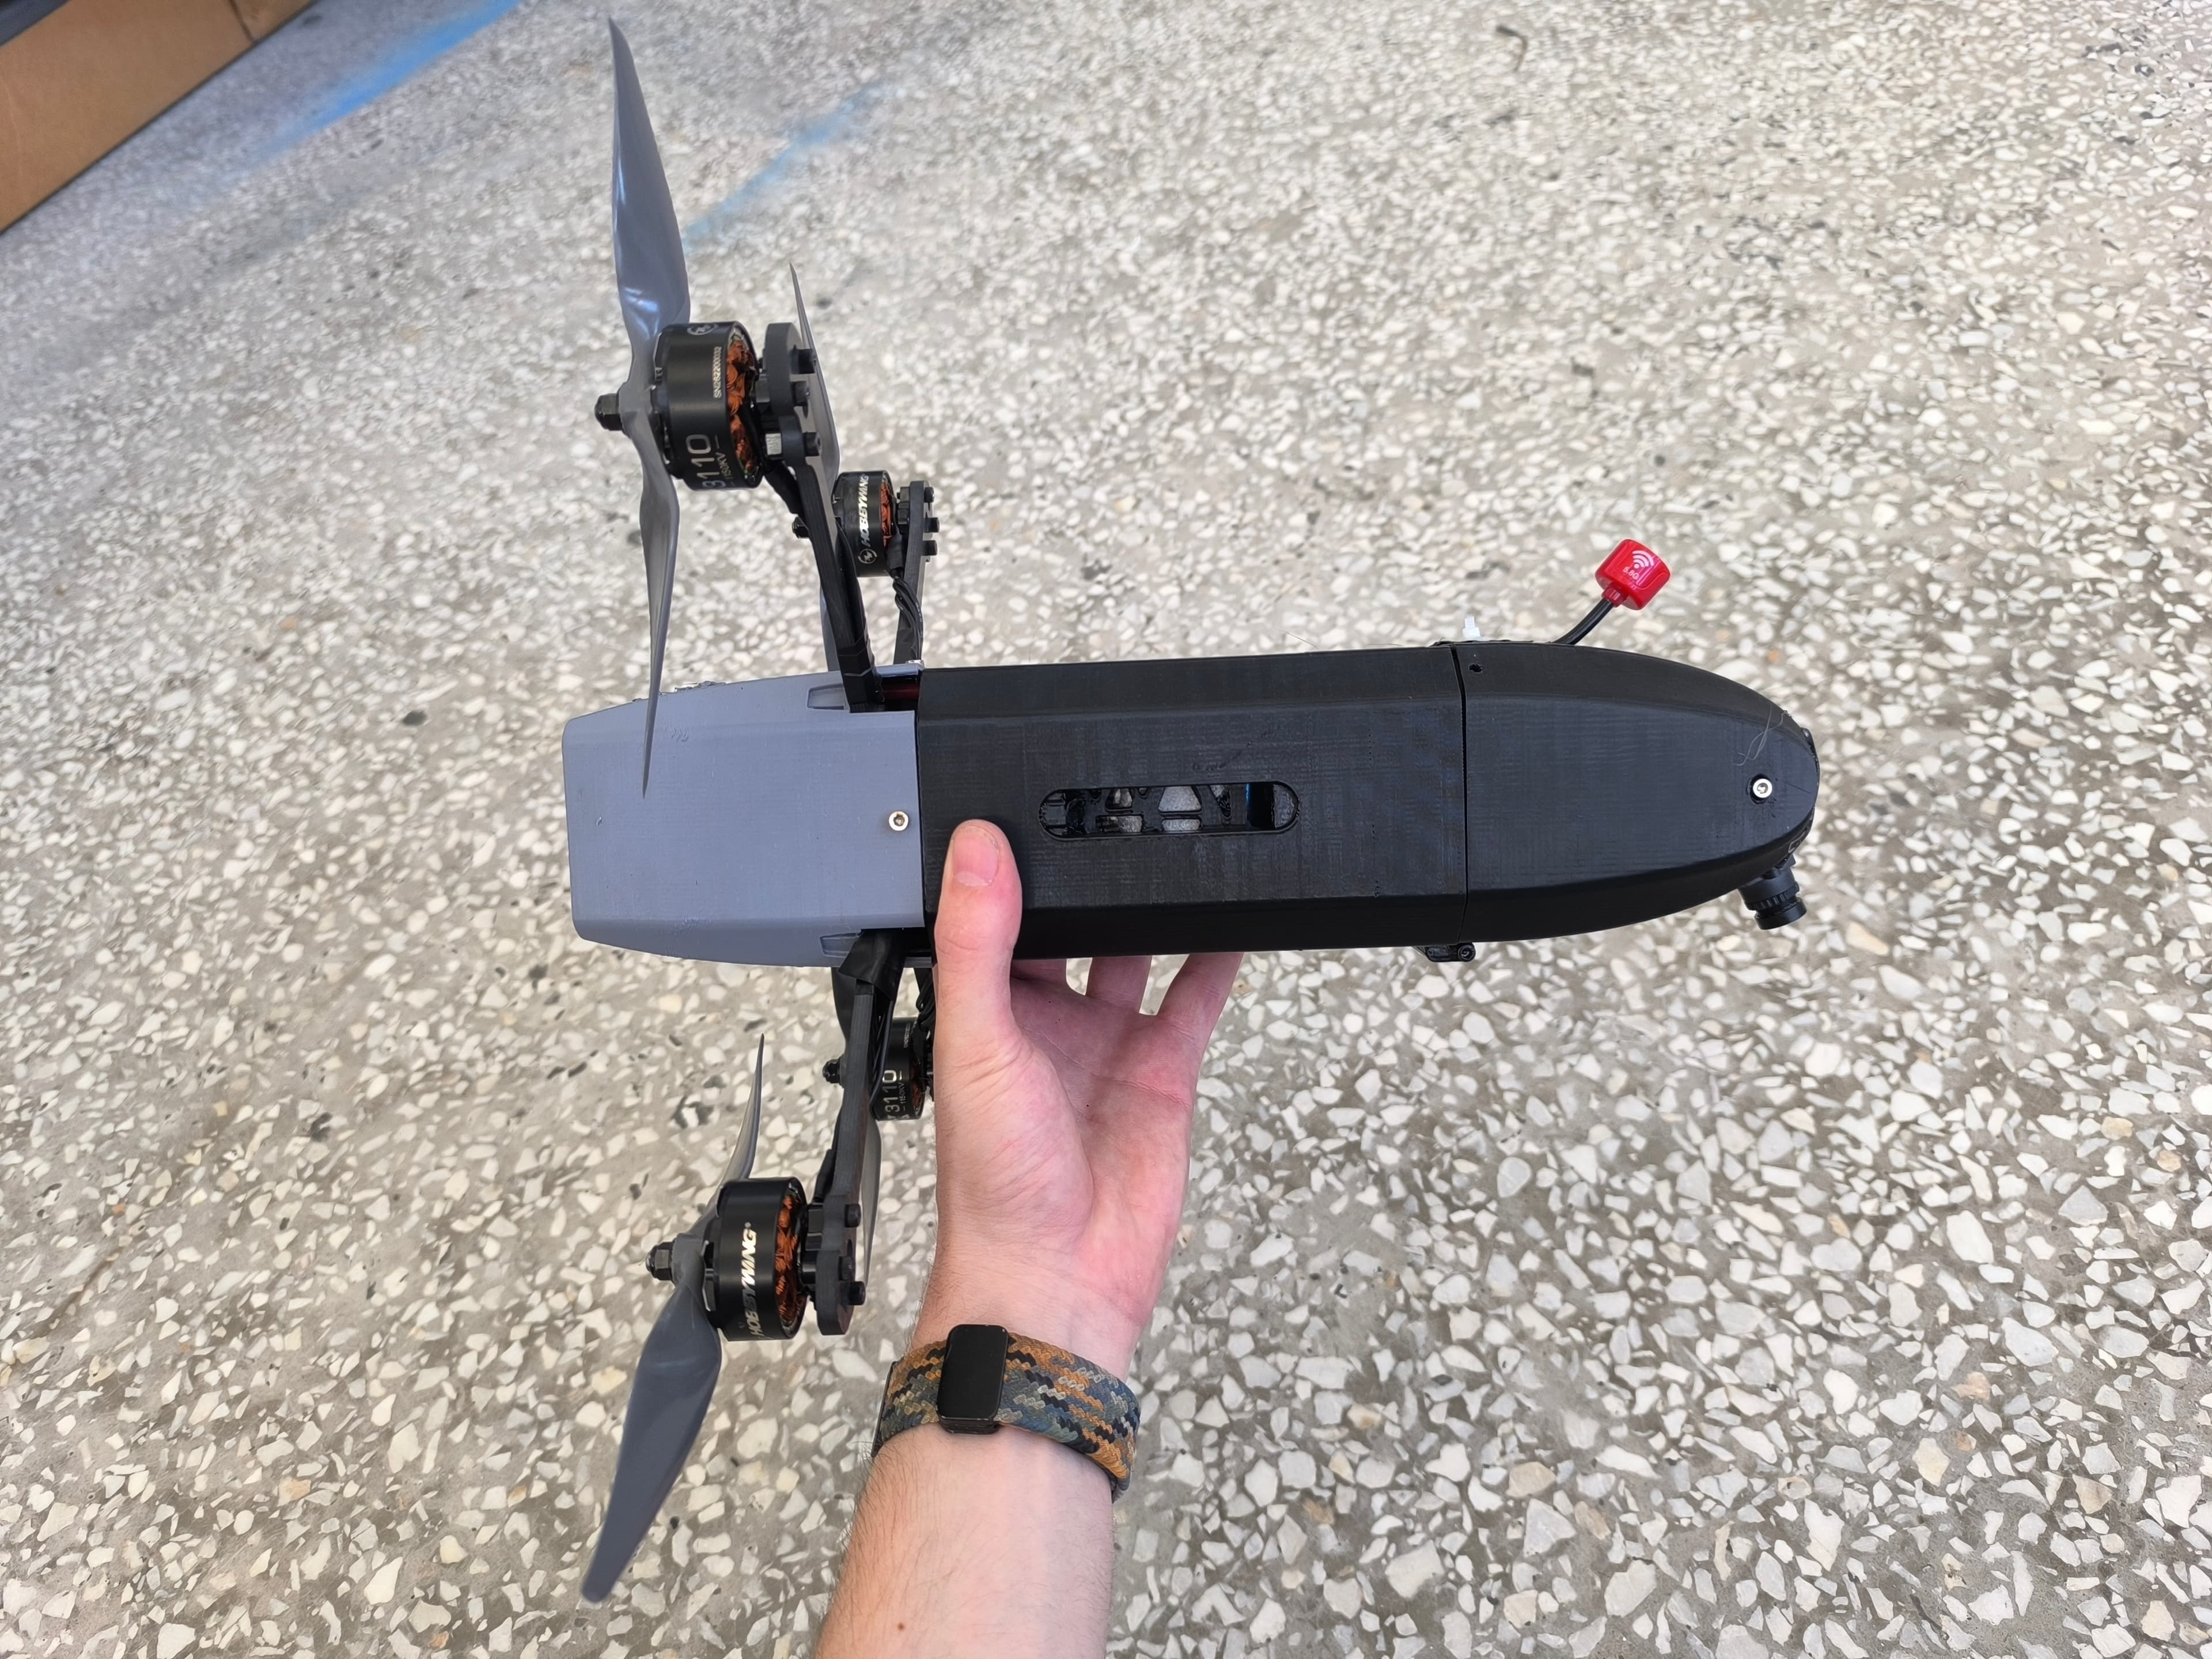
3D-printed 7-inch speed quadcopter — 300 km/h, 6.6 kW

From-scratch hybrid aircraft with custom-built wings and 3D-printed tilt rotors

Hybrid VTOL with separate lift and cruise motors for autonomous missions
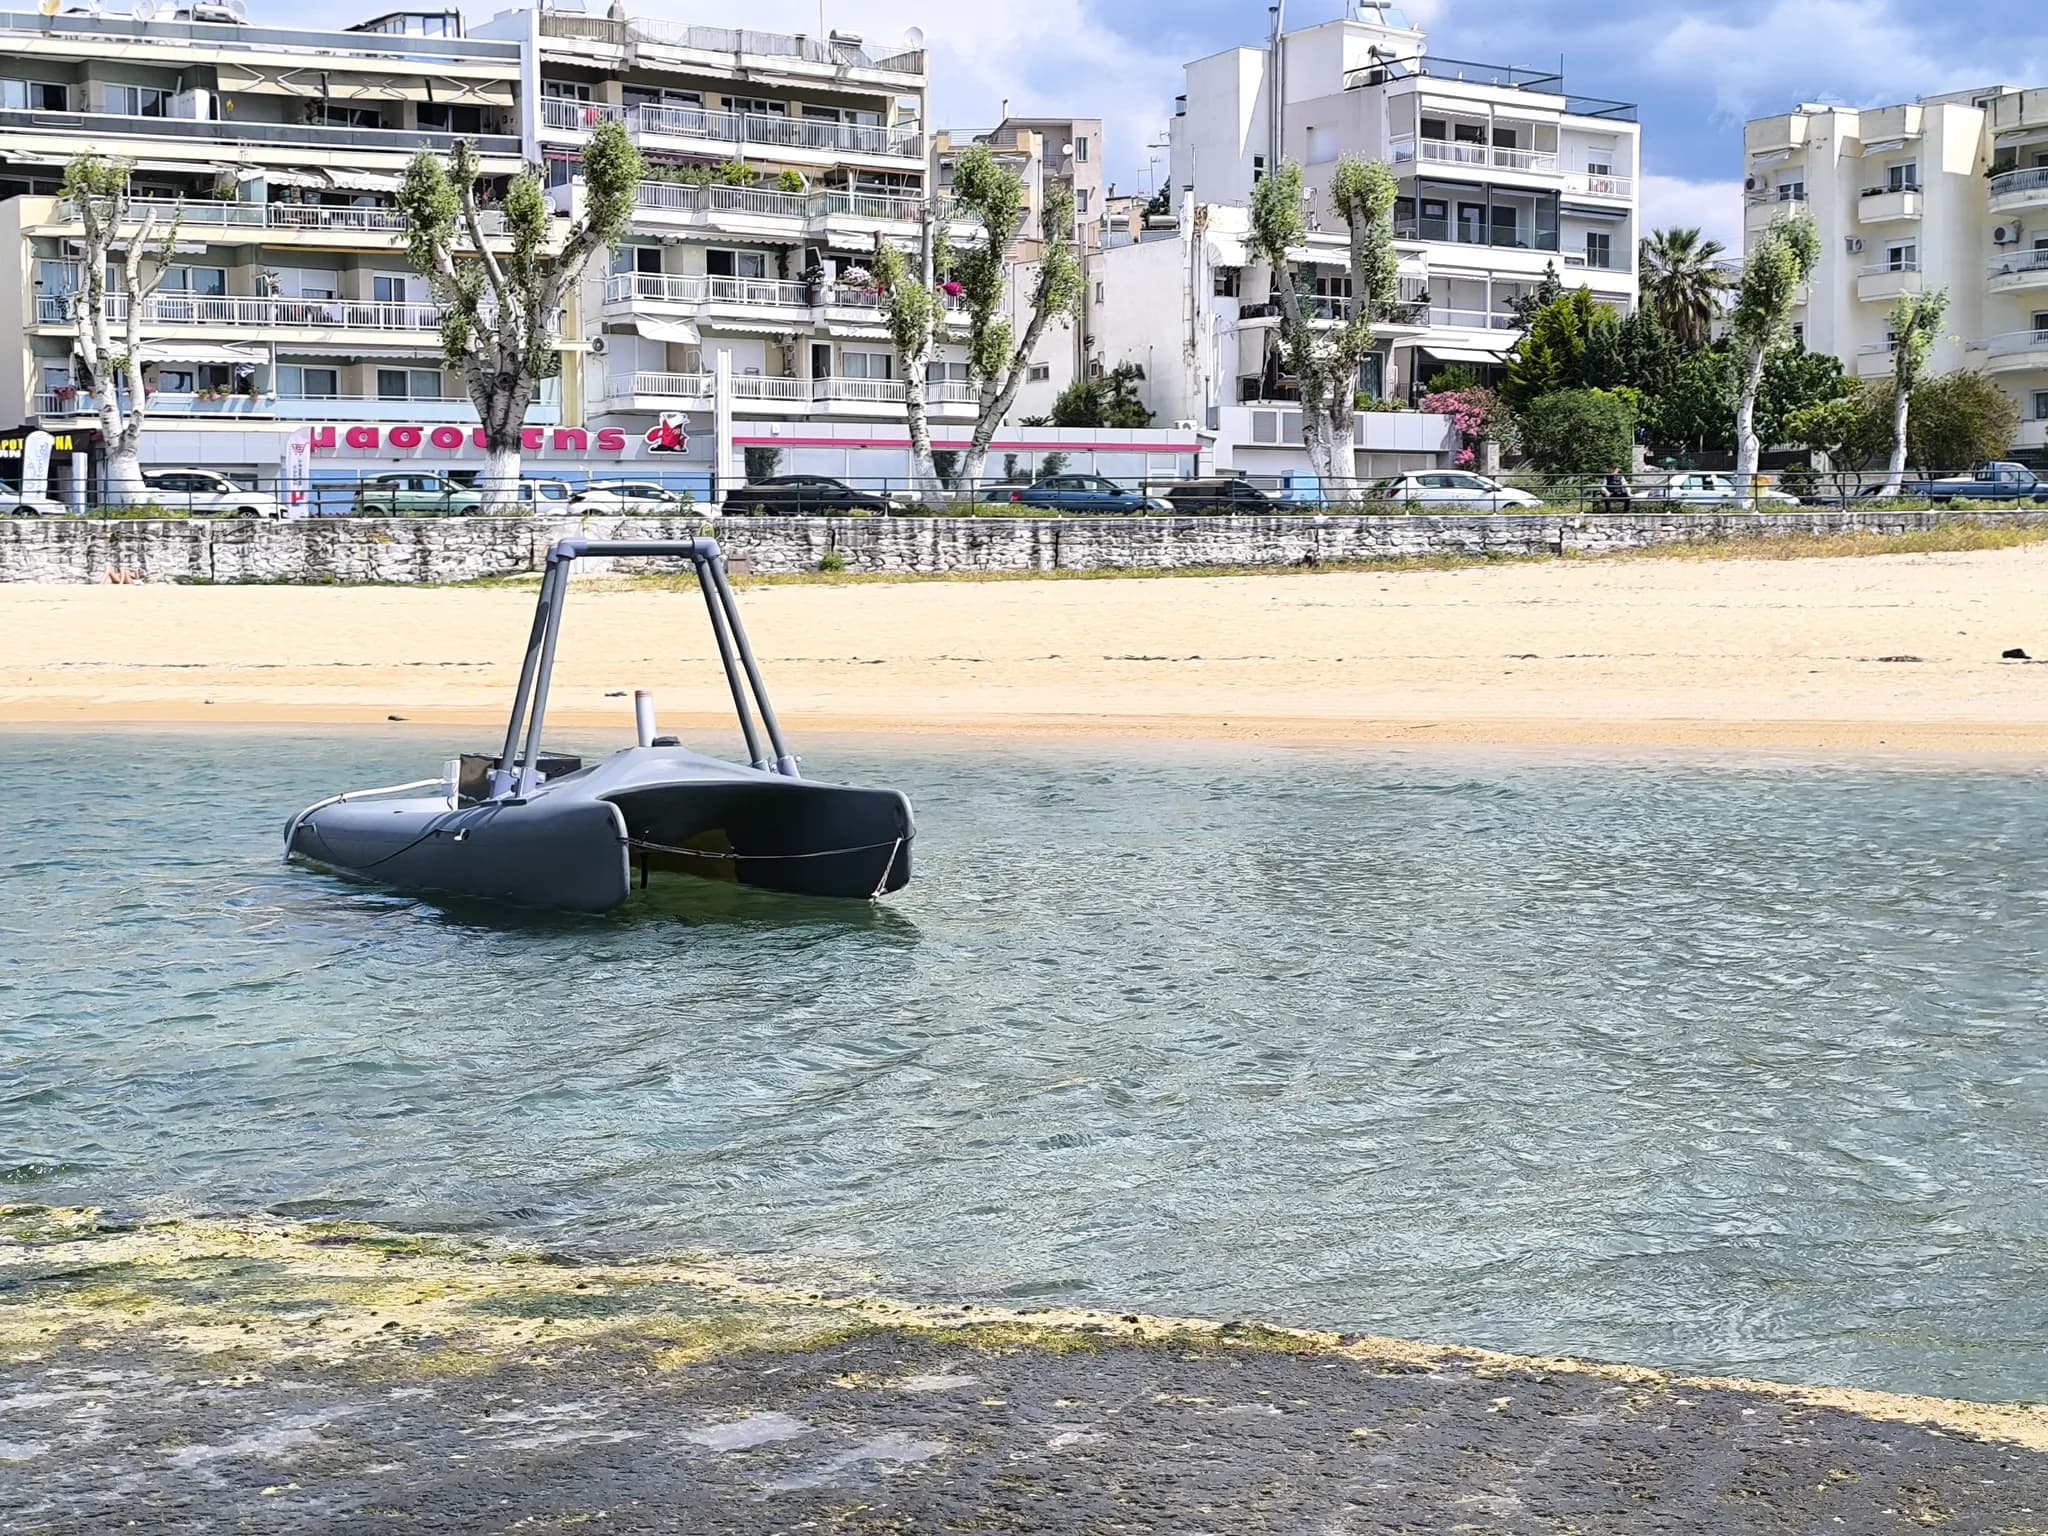
Autonomous surface vessel for maritime surveillance and search-and-rescue support

5-inch 4S FPV racing drone — 210 km/h, sub-450g
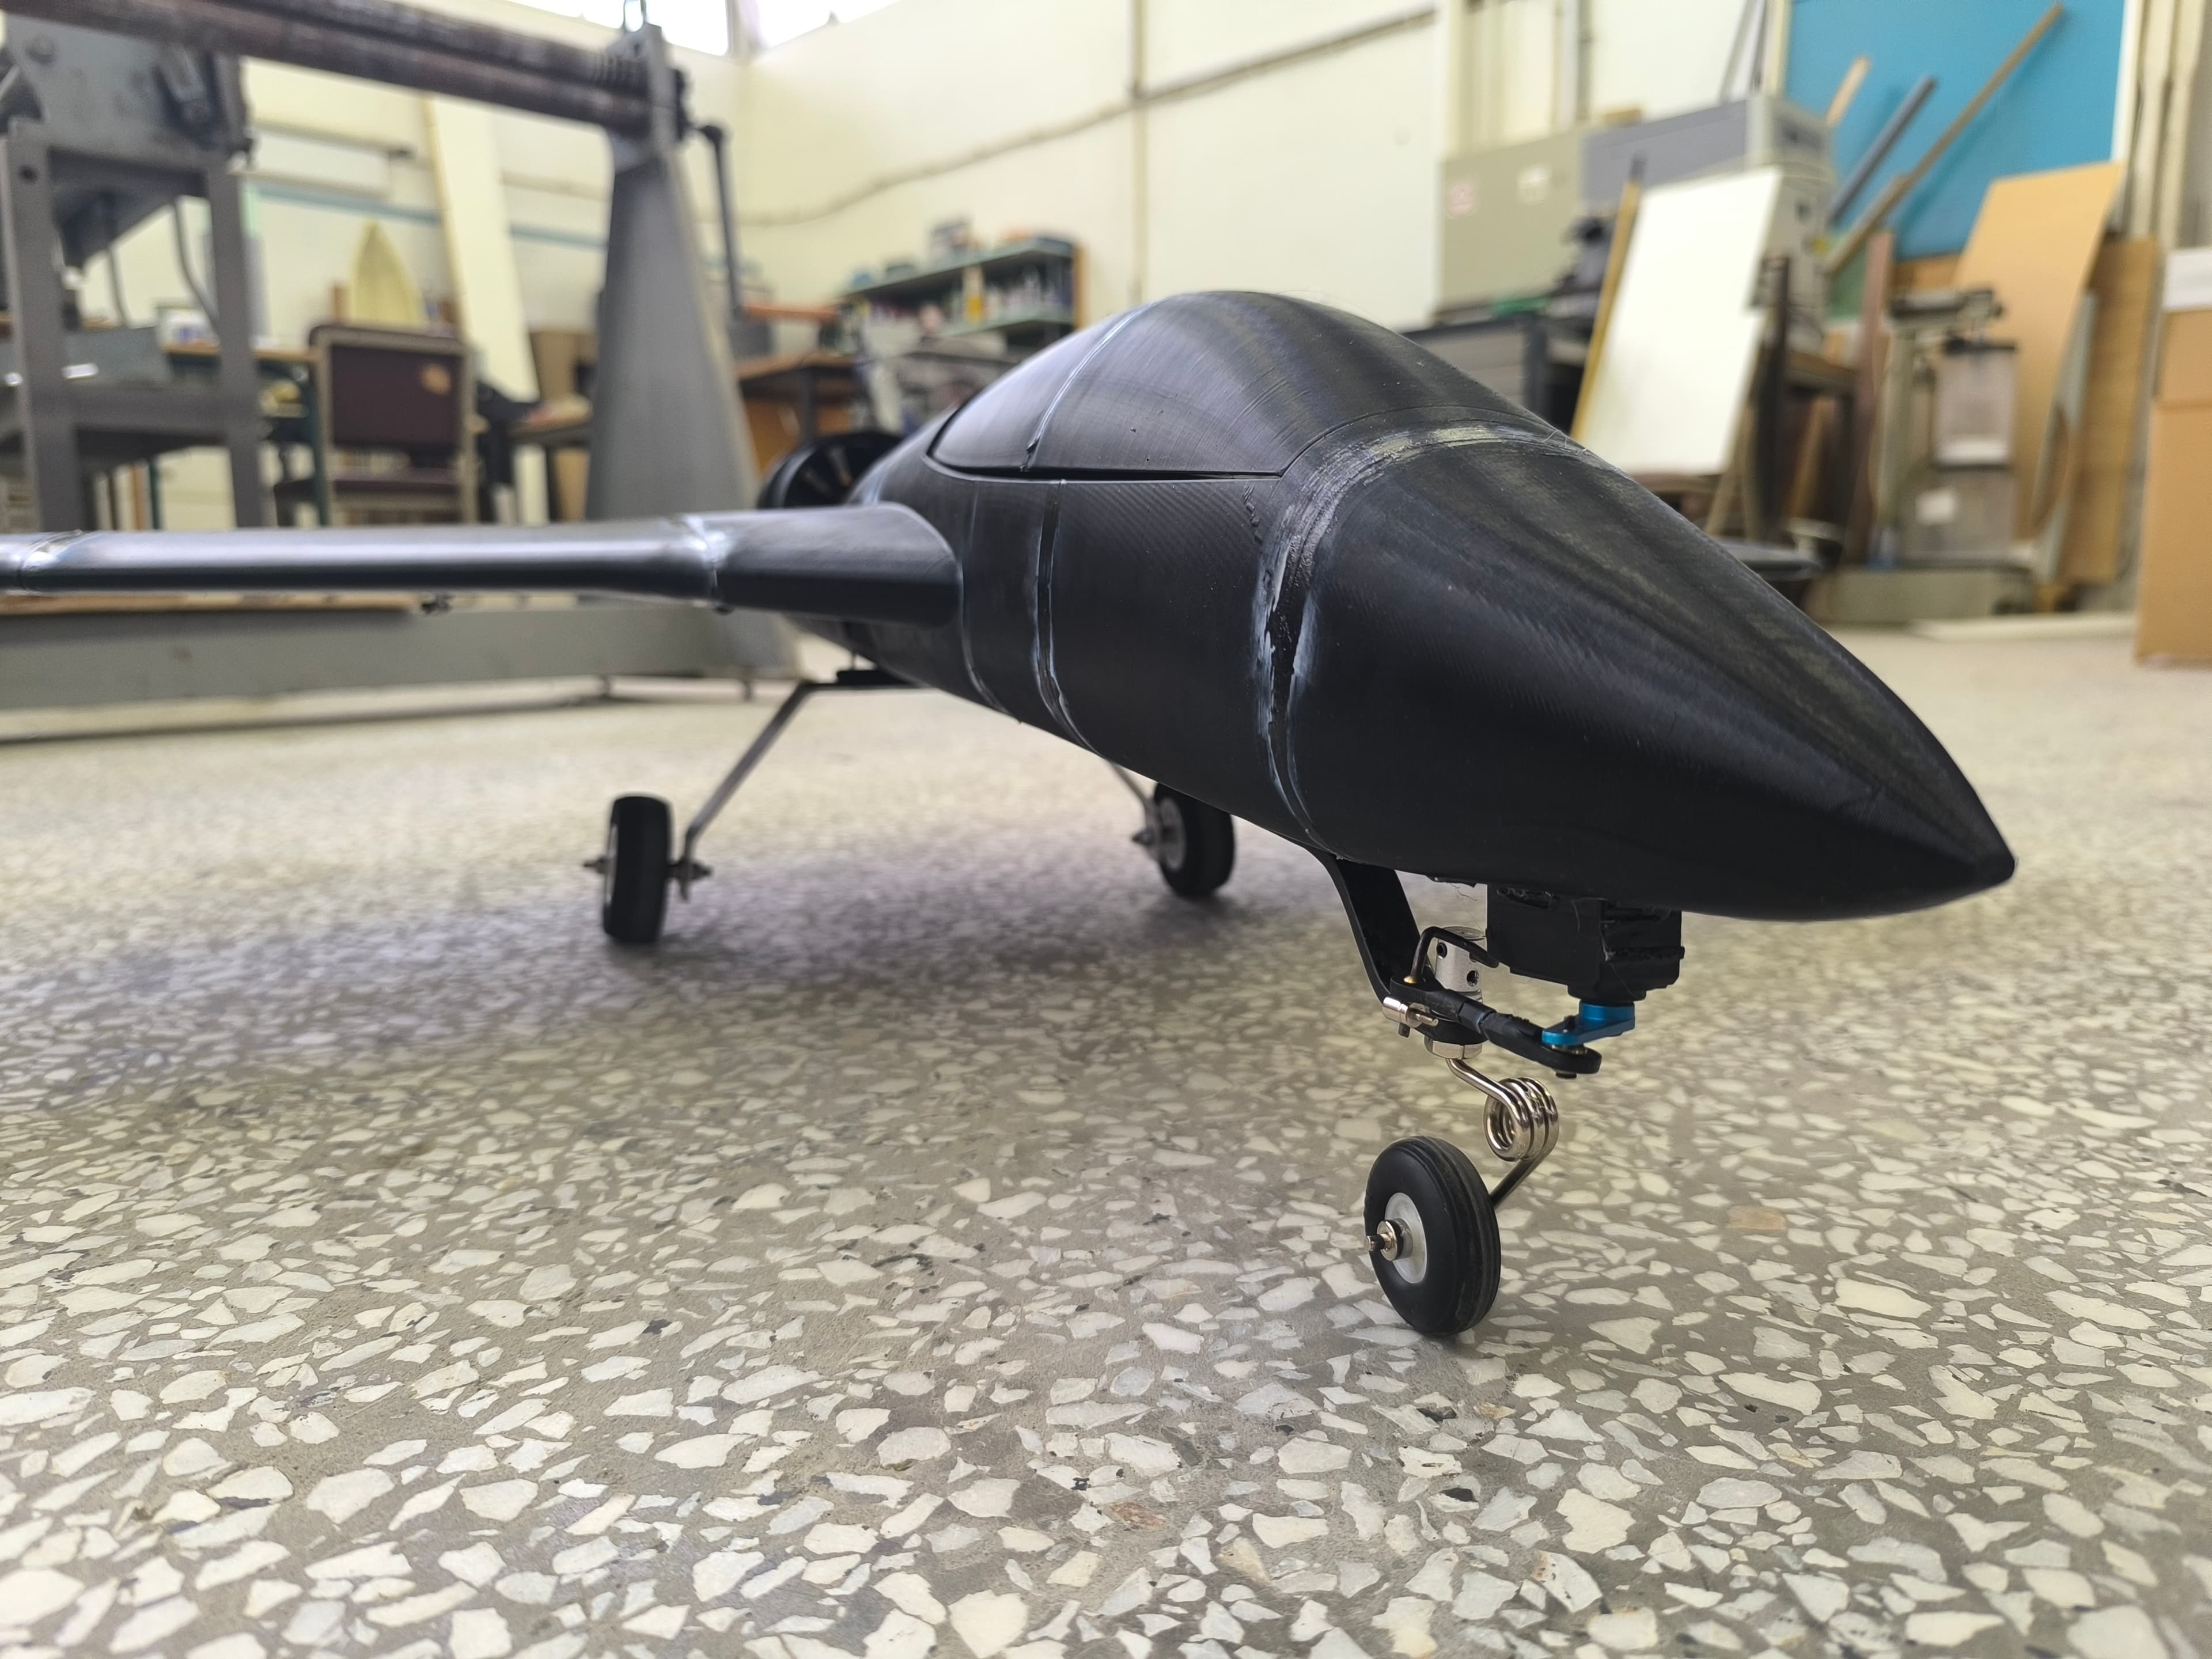
3D-printed 90mm EDF jet — 330 km/h, 2.5:1 thrust-to-weight
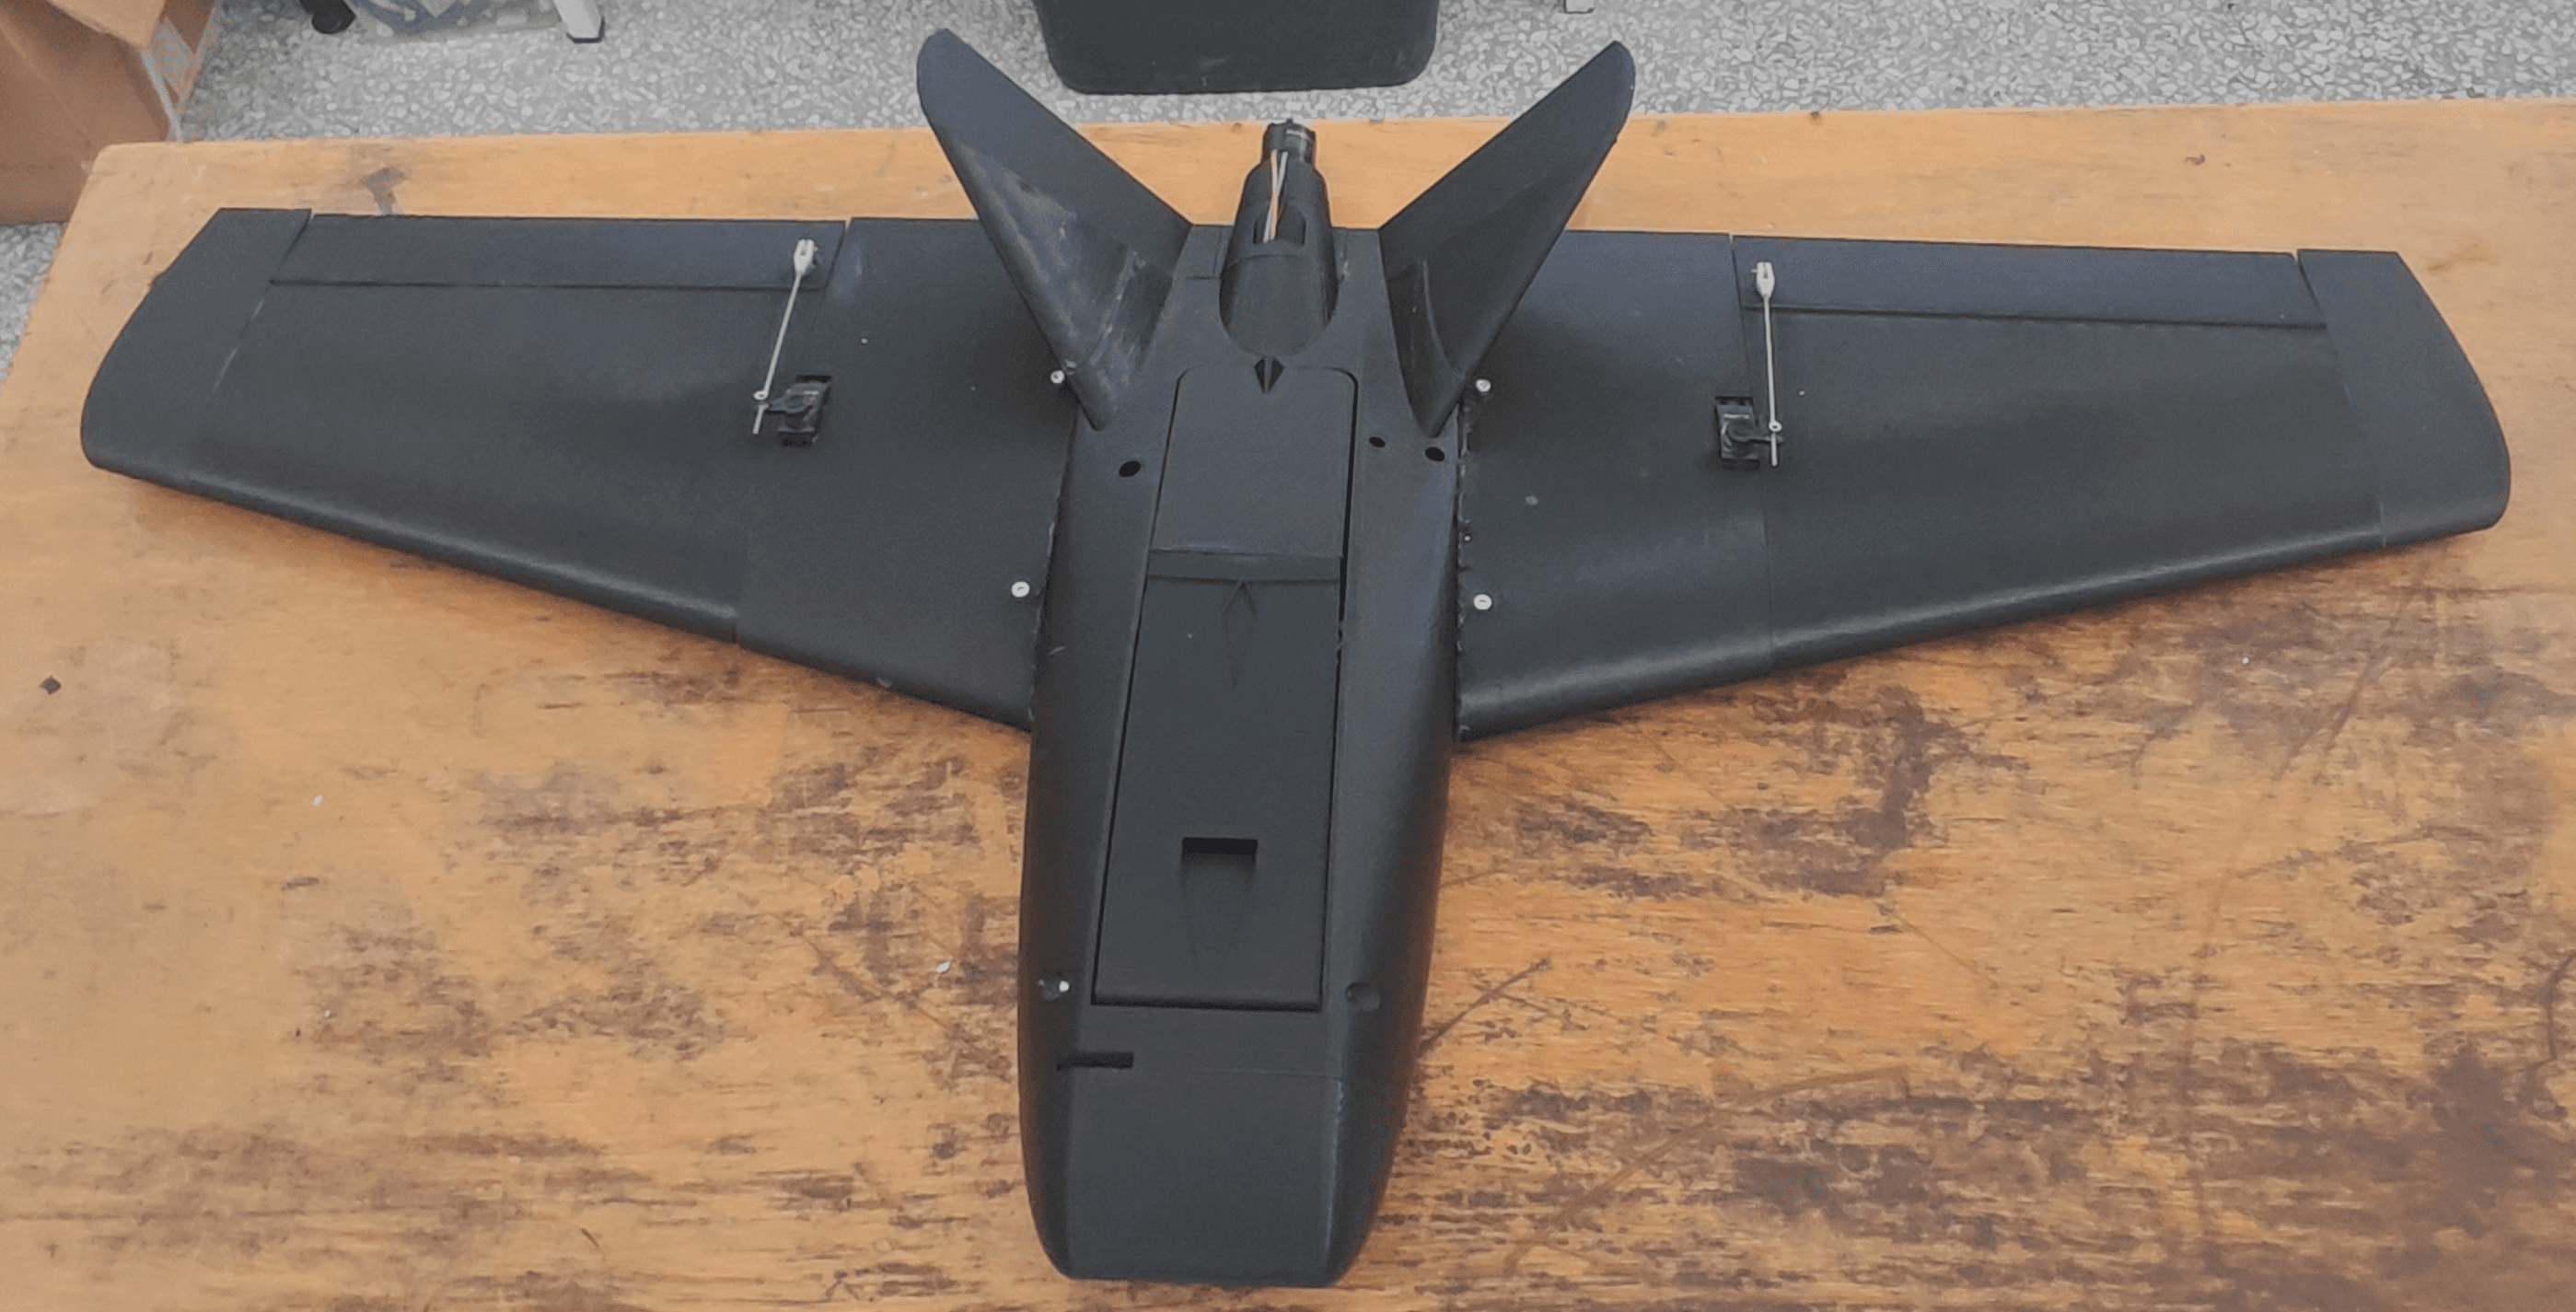
Fixed-wing UAV for real-time vehicle tracking in GPS-denied environments

GPS-denied 6-DOF pose estimation using camera features and IMU sensor fusion

Y6 coaxial hexacopter test platform for autonomous systems

From-scratch fixed-wing UAV with custom-built composite wings and 4+ hour endurance

Rust FPV system for Raspberry Pi — low-latency H.264 over raw 802.11

EEG-based biometric authentication binding GPG keys to brainwave patterns

Deep RL-based attitude control for quadrotors deployed on bare-metal MCUs
Open to research collaborations, robotics projects, and applied ML work.